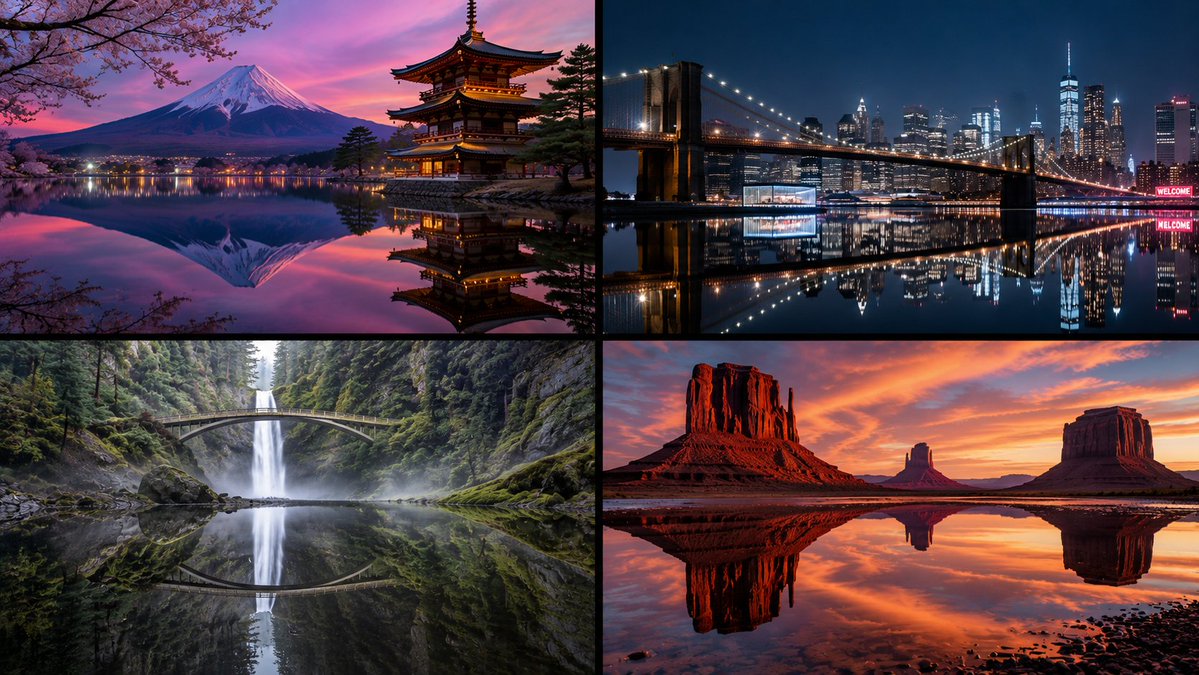
2x2 grid, 16:9, do this for 4 completely different scenes: Π = reflecting plane: point...
2x2 grid, 16:9, do this for 4 completely different scenes: Π = reflecting plane: point q, unit normal m R(x) = x − 2((x−q)·m) m (reflection across Π) reflected image = scene imaged by the VIRTUAL camera R(C); every real feature f has twin R(f) RENDERED • reflection is a BIJECTION of the scene across Π; occlusion order reverses • points on Π are fixed → the waterline is self-coincident • chirality FLIPS — text and hands are mirror-reversed • a vertical object inverts about the waterline; base-of-object meets base-of-reflection exactly on Π • perspective in the reflection is that of R(C): the same vanishing points, mapped READ OFF • k real↔reflected correspondences: each pair's perpendicular-bisector plane must be the SAME Π • reflected height / compression is lawful with view angle, not free • everything in front of Π that R(C) can see appears — and nothing else CONSISTENCY recover (m̂, q̂) from correspondence pairs — must coincide; check handedness of every reflected glyph FORBIDDEN: a reflection containing an object with NO real pre-image (or dropping one plainly in front); signage readable forward in the glass; reflected pose / expression differing from the subject; a floating reflection whose base does not meet the object on Π.